$$
% Define your custom commands here
\newcommand{\bmat}[1]{\begin{bmatrix}#1\end{bmatrix}}
\newcommand{\E}{\mathbb{E}}
\newcommand{\P}{\mathbb{P}}
\newcommand{\S}{\mathbb{S}}
\newcommand{\R}{\mathbb{R}}
\newcommand{\S}{\mathbb{S}}
\newcommand{\norm}[2]{\|{#1}\|_{{}_{#2}}}
\newcommand{\pd}[2]{\frac{\partial #1}{\partial #2}}
\newcommand{\pdd}[2]{\frac{\partial^2 #1}{\partial #2^2}}
\newcommand{\vectornorm}[1]{\left|\left|#1\right|\right|}
\newcommand{\abs}[1]{\left|{#1}\right|}
\newcommand{\mbf}[1]{\mathbf{#1}}
\newcommand{\mc}[1]{\mathcal{#1}}
\newcommand{\bm}[1]{\boldsymbol{#1}}
\newcommand{\nicefrac}[2]{{}^{#1}\!/_{\!#2}}
\newcommand{\argmin}{\operatorname*{arg\,min}}
\newcommand{\argmax}{\operatorname*{arg\,max}}
\newcommand{\dd}{\operatorname{d}\!}
$$
Meet the graduate students in the Robot Control Lab at UT Dallas.
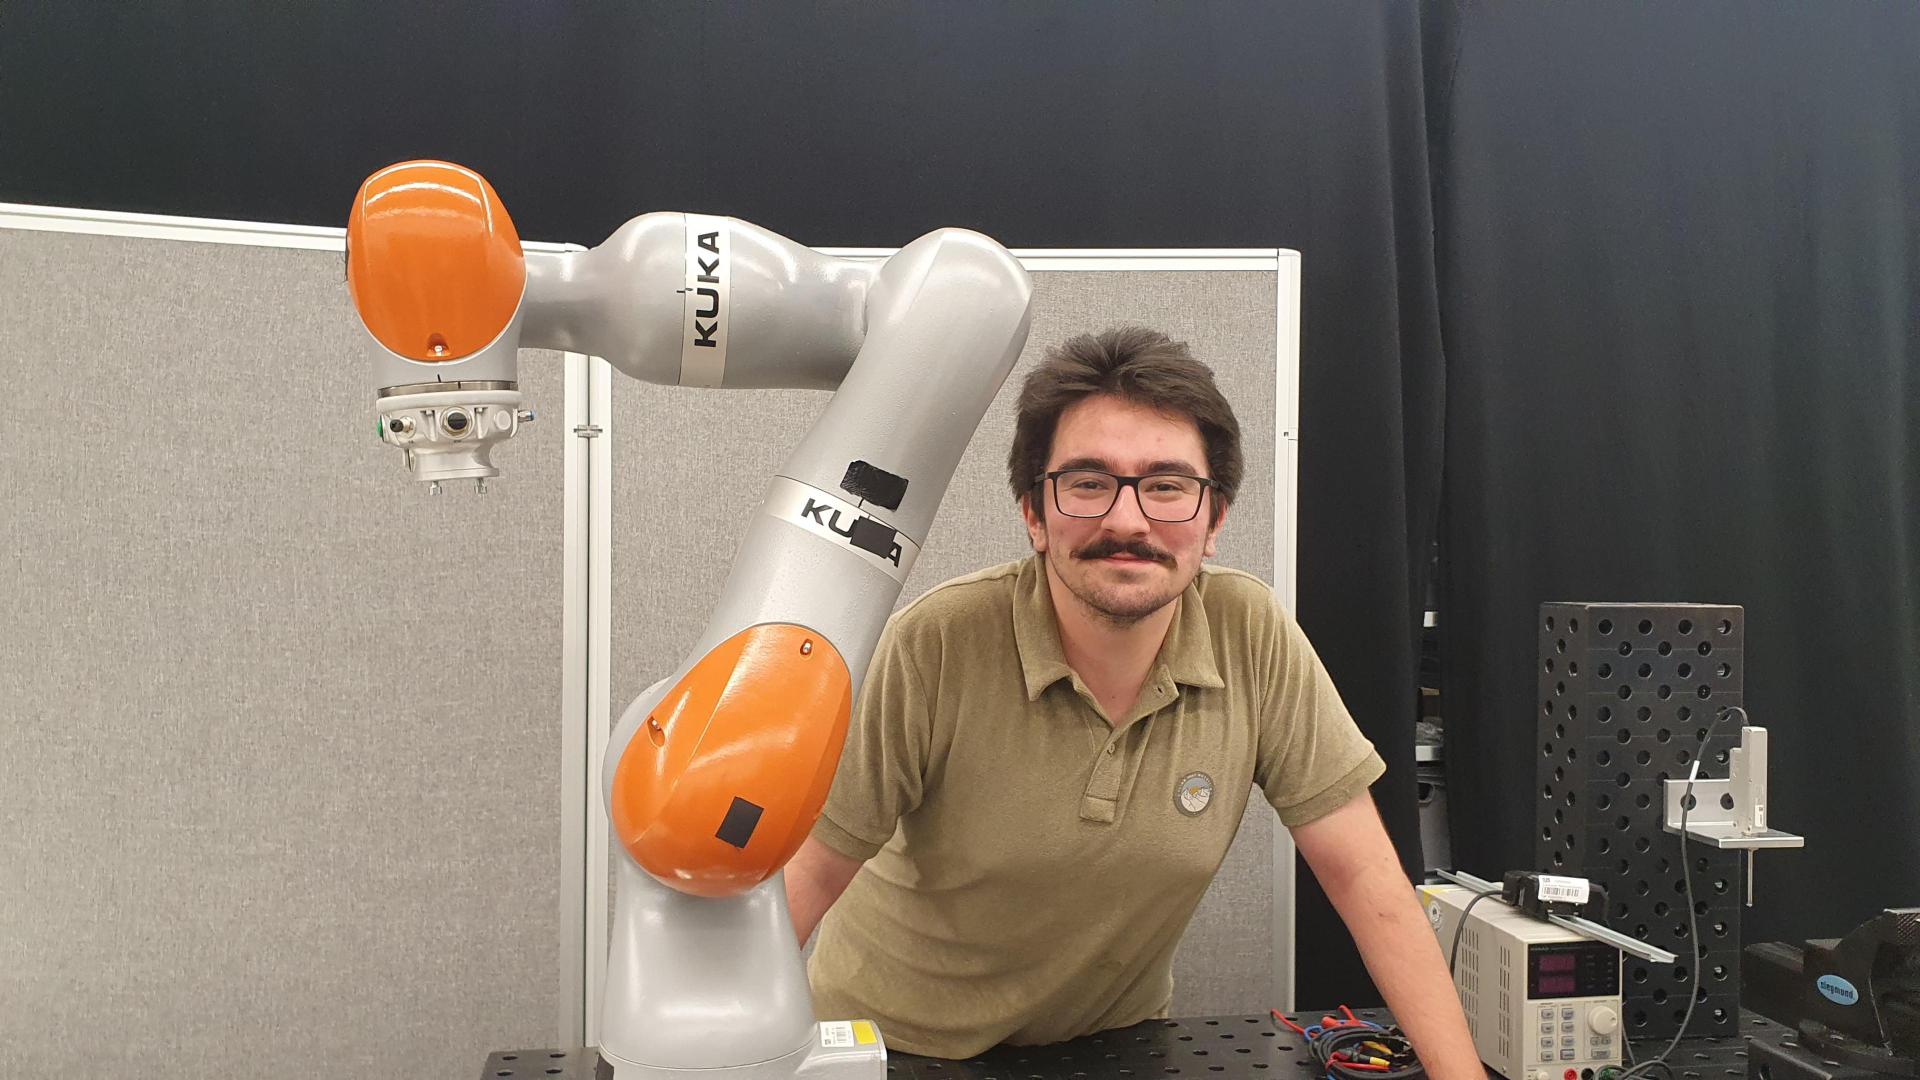
Yunus Emre Danabas
Ph.D. student
Joined Fall 2026
B.S. (double major), Mechatronics Engineering and Electronics Engineering, Sabancı University, Istanbul.
Angelo Matthew Mariano Pimienta
Ph.D. student
Joined Fall 2026
B.S. and M.S., Computer Science, The University of Texas at Dallas.
Meet the full group · Graduate alumni